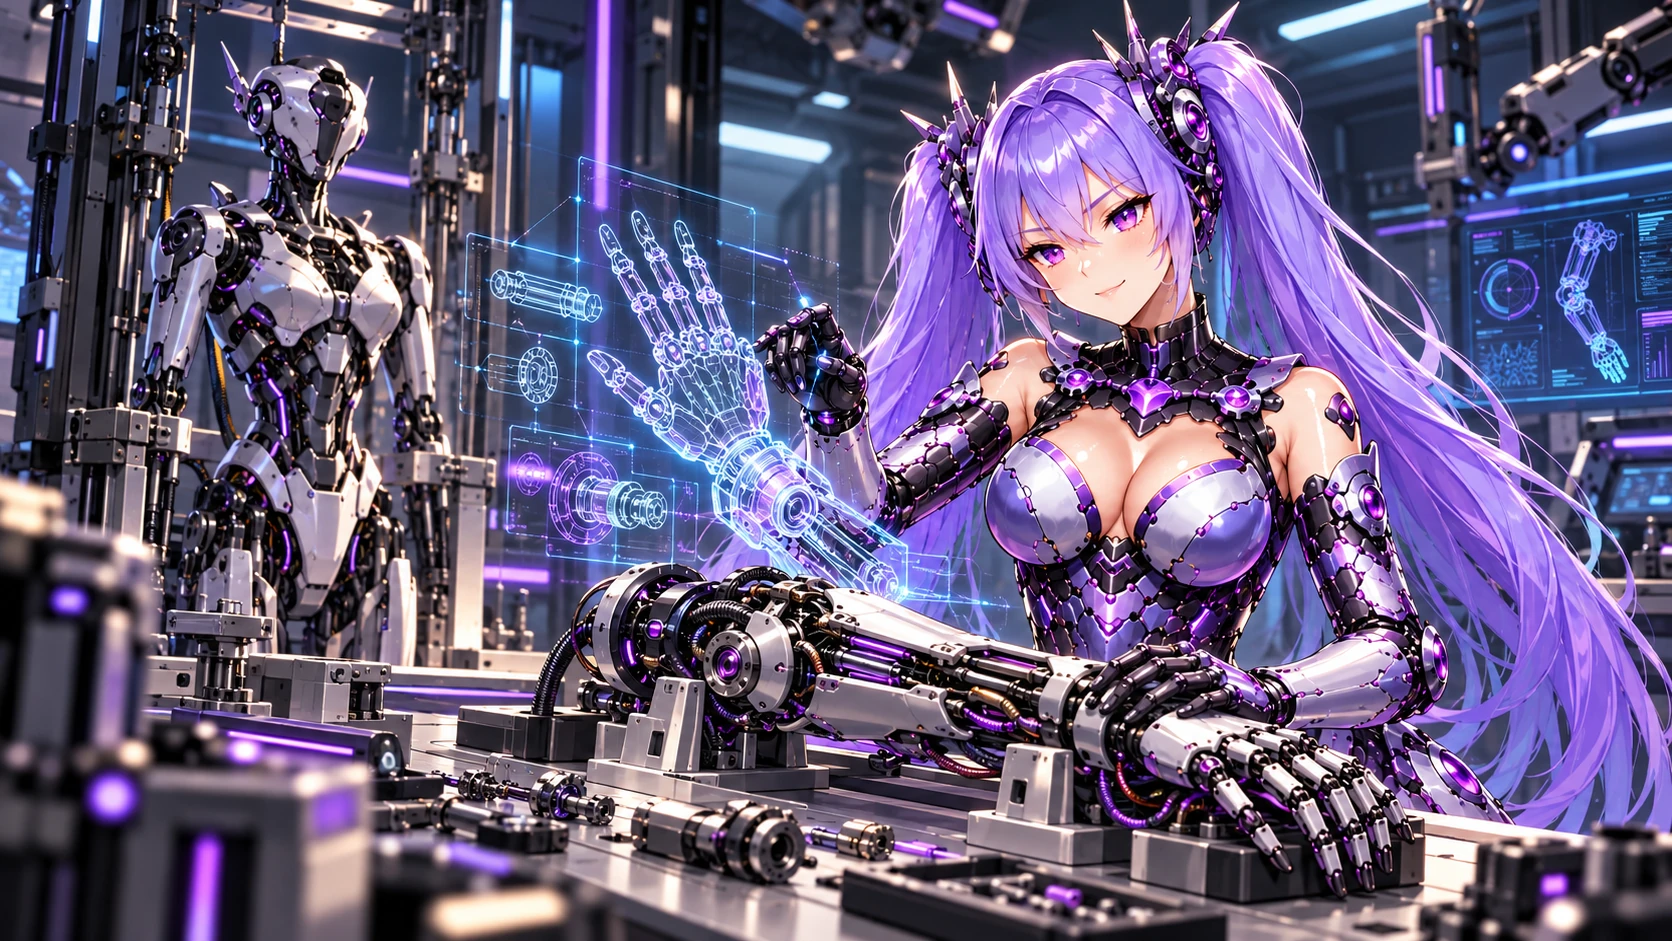
An experimental direction for connecting Gynara identities to future physical chassis. The current website does not operate a deployed humanoid stack.
ExperimentalPractitionerUpdated 2026-10-30
Experimental note. This is research or an earlier design, not evidence of the website's current implementation.
01 / WHAT
What it does
Drakima already supplies character identities, conversation, voice and visual presentation. Physical embodiment is a separate research program involving sensors, mechanisms, real-time control and measurable safety boundaries.
02 / WHY
Why it works this way
Conversational fluency is not evidence that a model can safely move hardware. The future architecture must distinguish a proposed intention from an authorized physical action.
03 / HOW
How it works
Begin with versioned interfaces and simulation. A language model may propose a bounded, expiring skill; deterministic owners validate observations, capability and limits before execution. An independent supervisor retains stop authority outside the conversational model and network.
Progress from contract tests and recorded sensor replay to fault-injected simulation, hardware-in-the-loop and carefully bounded physical trials. Measure watchdog behavior, stale-data rejection, motion limits and recovery for the actual hardware. Preserve identity continuity without treating private conversation data as unrestricted robot telemetry.
This is a proposed direction, not a claim of completed chassis, actuator integration or hardware certification. Gynoid illustrations depict the Gynara universe and possible engineering work; they are concept art.
View the diagram and flowHow the parts connectConceptual flow of the current ownership boundary; not a live status display.
01
Software identity
Current conversation and presentation capabilities
02
Typed proposal
Future bounded skill request
03
Validation
Future deterministic permission and freshness checks
04
Control and supervision
Future hardware-specific execution and stop authority
05
Measured evidence
Separate simulation and physical acceptance
IMPLEMENTATION SAMPLES
Inspect the code examples
Contract at a glancetext
Current: website, identities, voice, media and authoring
Research: embodied skills and hardware interfaces
Required before physical use: measured independent control and acceptance
Illustrative contract summary. This is not an executable script or a record of a live operation.